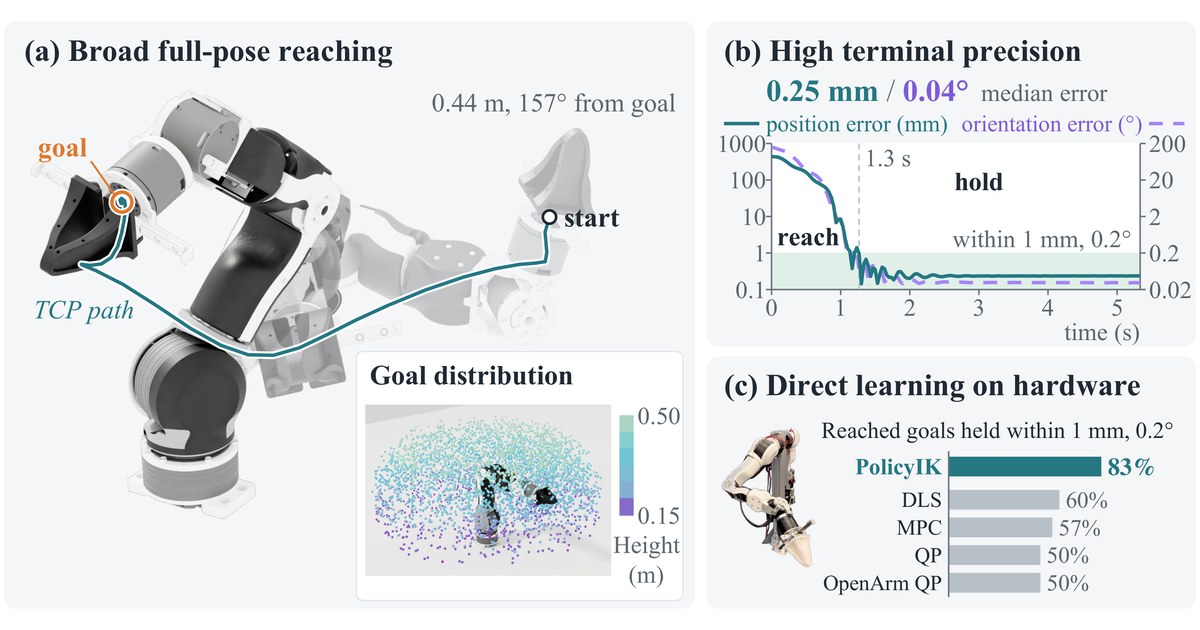
PolicyIK
High-Precision Inverse Kinematics for Robot Arms with Reinforcement Learning
Yuhan Liu*, Xinqi Liu*, Zixuan Dong*, Keith W. Ross, Shenji Wan
* Equal contribution
A goal-conditioned reinforcement learning approach to high-precision inverse kinematics,
enabling robot arms to reach and hold target poses in simulation and on physical hardware,
with applications to vision-language-action manipulation.
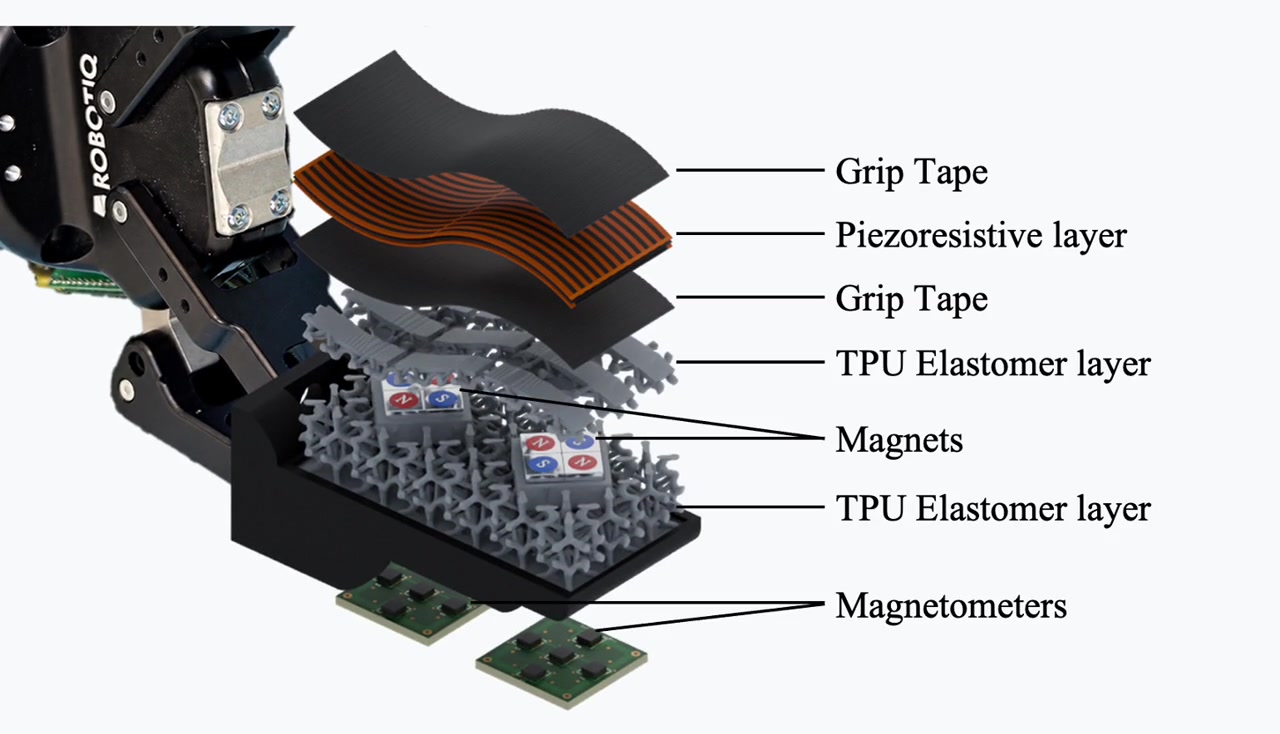
PanoTac
A Dense Three-Axis Tactile Sensor for Robust Touch-Centric Manipulation
Binglin (Andre) Wang, Xiaole Jiang, Zicheng Teng, Xinqi Liu,
Yunzhu Li, Lerrel Pinto, Zichen Jeff Cui, Binghao Huang
A low-cost, compliant tactile fingertip combining dense normal and shear feedback
for touch-centric robot manipulation, including test tube preparation, grain scooping,
and salt pouring.
Accepted · IEEE Humanoids 2026
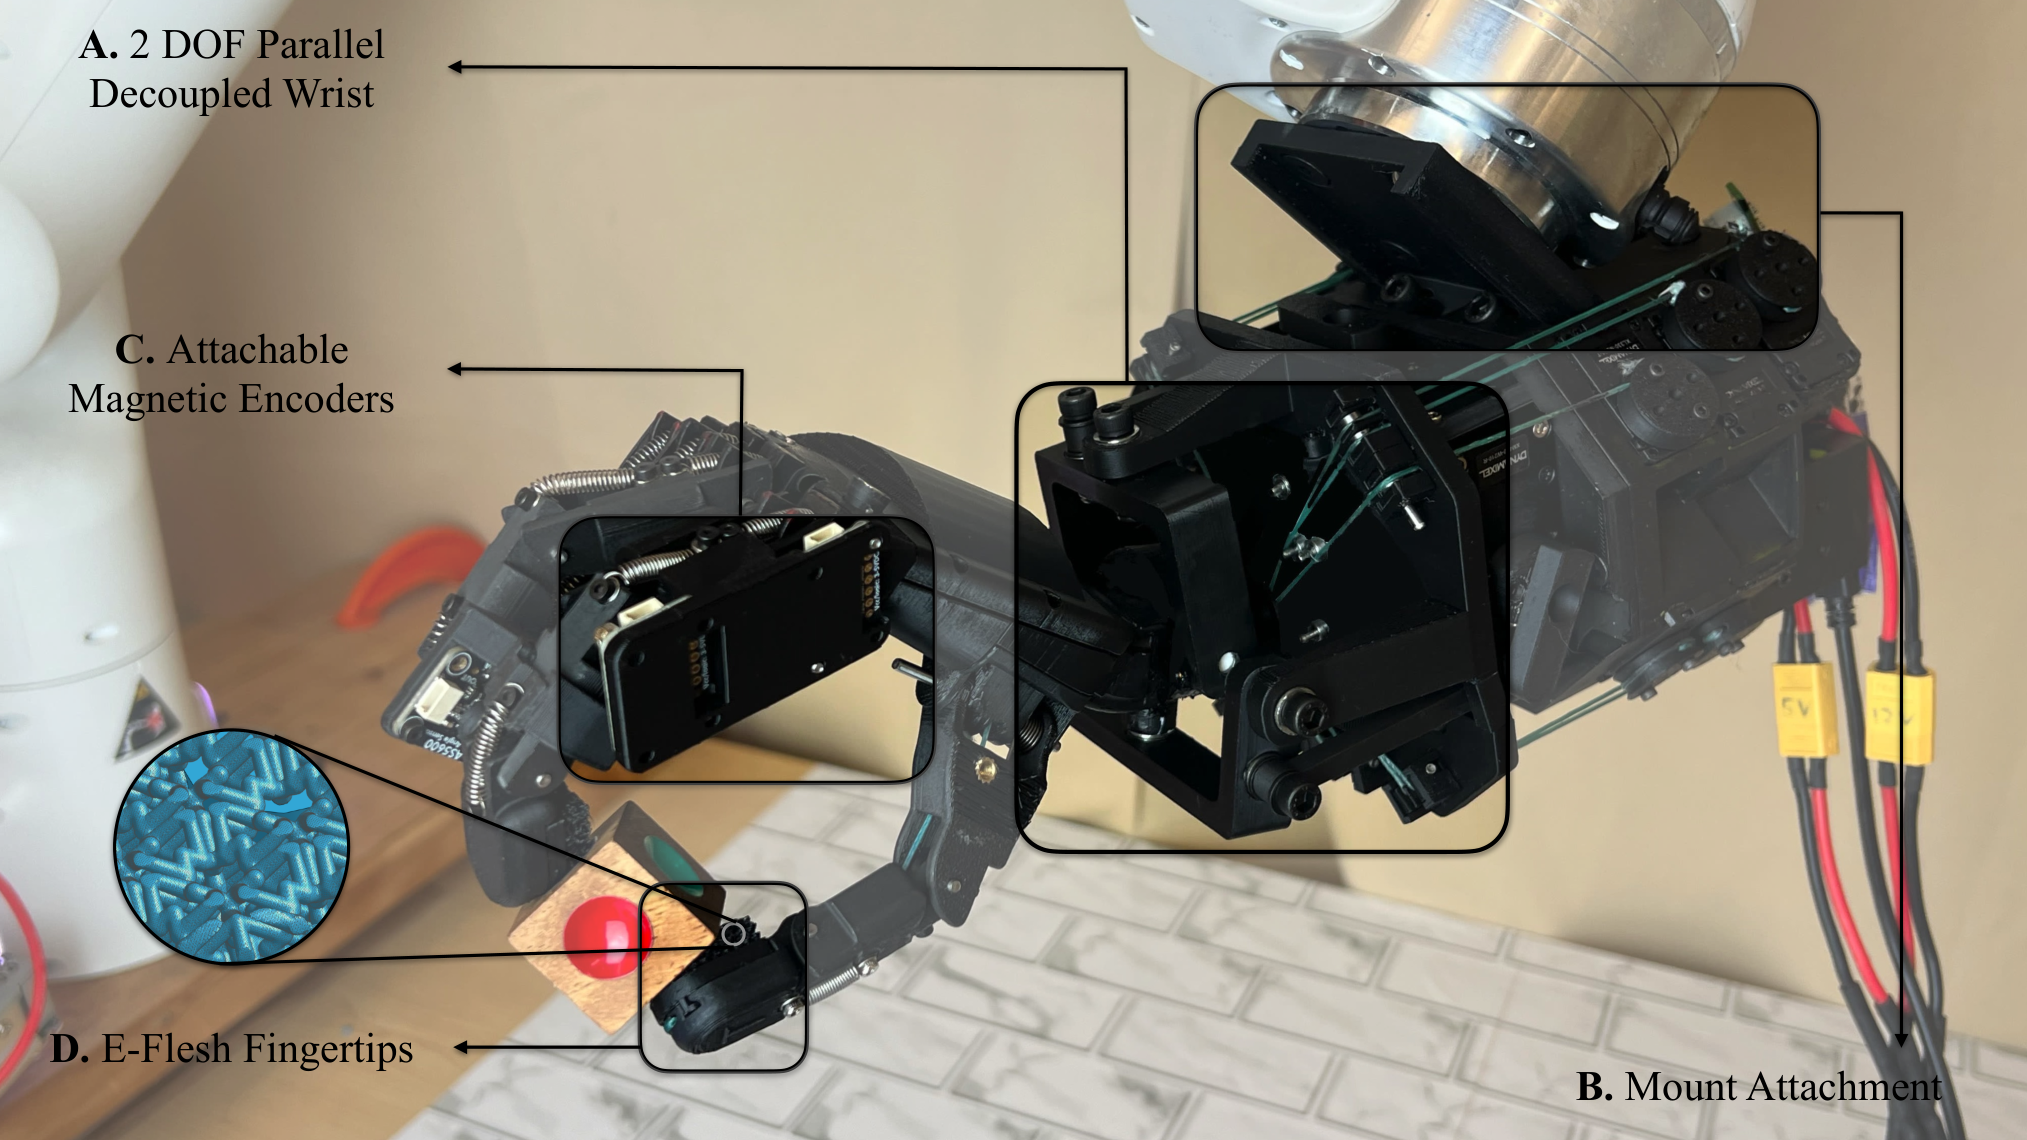
RUKA-v2
Tendon Driven Open-Source Dexterous Hand with Wrist and Abduction for Robot Learning
Xinqi Liu, Ruoxi Hu, Alejandro Ojeda Olarte, Zhuoran Chen, Kenny Ma,
Charles Cheng Ji, Lerrel Pinto, Raunaq Bhirangi, Irmak Guzey
ICRA Workshop · Spotlight
An open-source, tendon-driven humanoid hand with a decoupled 2-DOF wrist
and finger abduction/adduction for dexterous teleoperation and robot learning.
More projects and publications coming soon.